JUSTIN YIN / SELECTED WORK
A record of
making.
An evolving portfolio of the engineering work I design and document. It begins with my FRC robot: its mechanisms, revisions, and the files behind the full assembly.
OPEN THE INDEX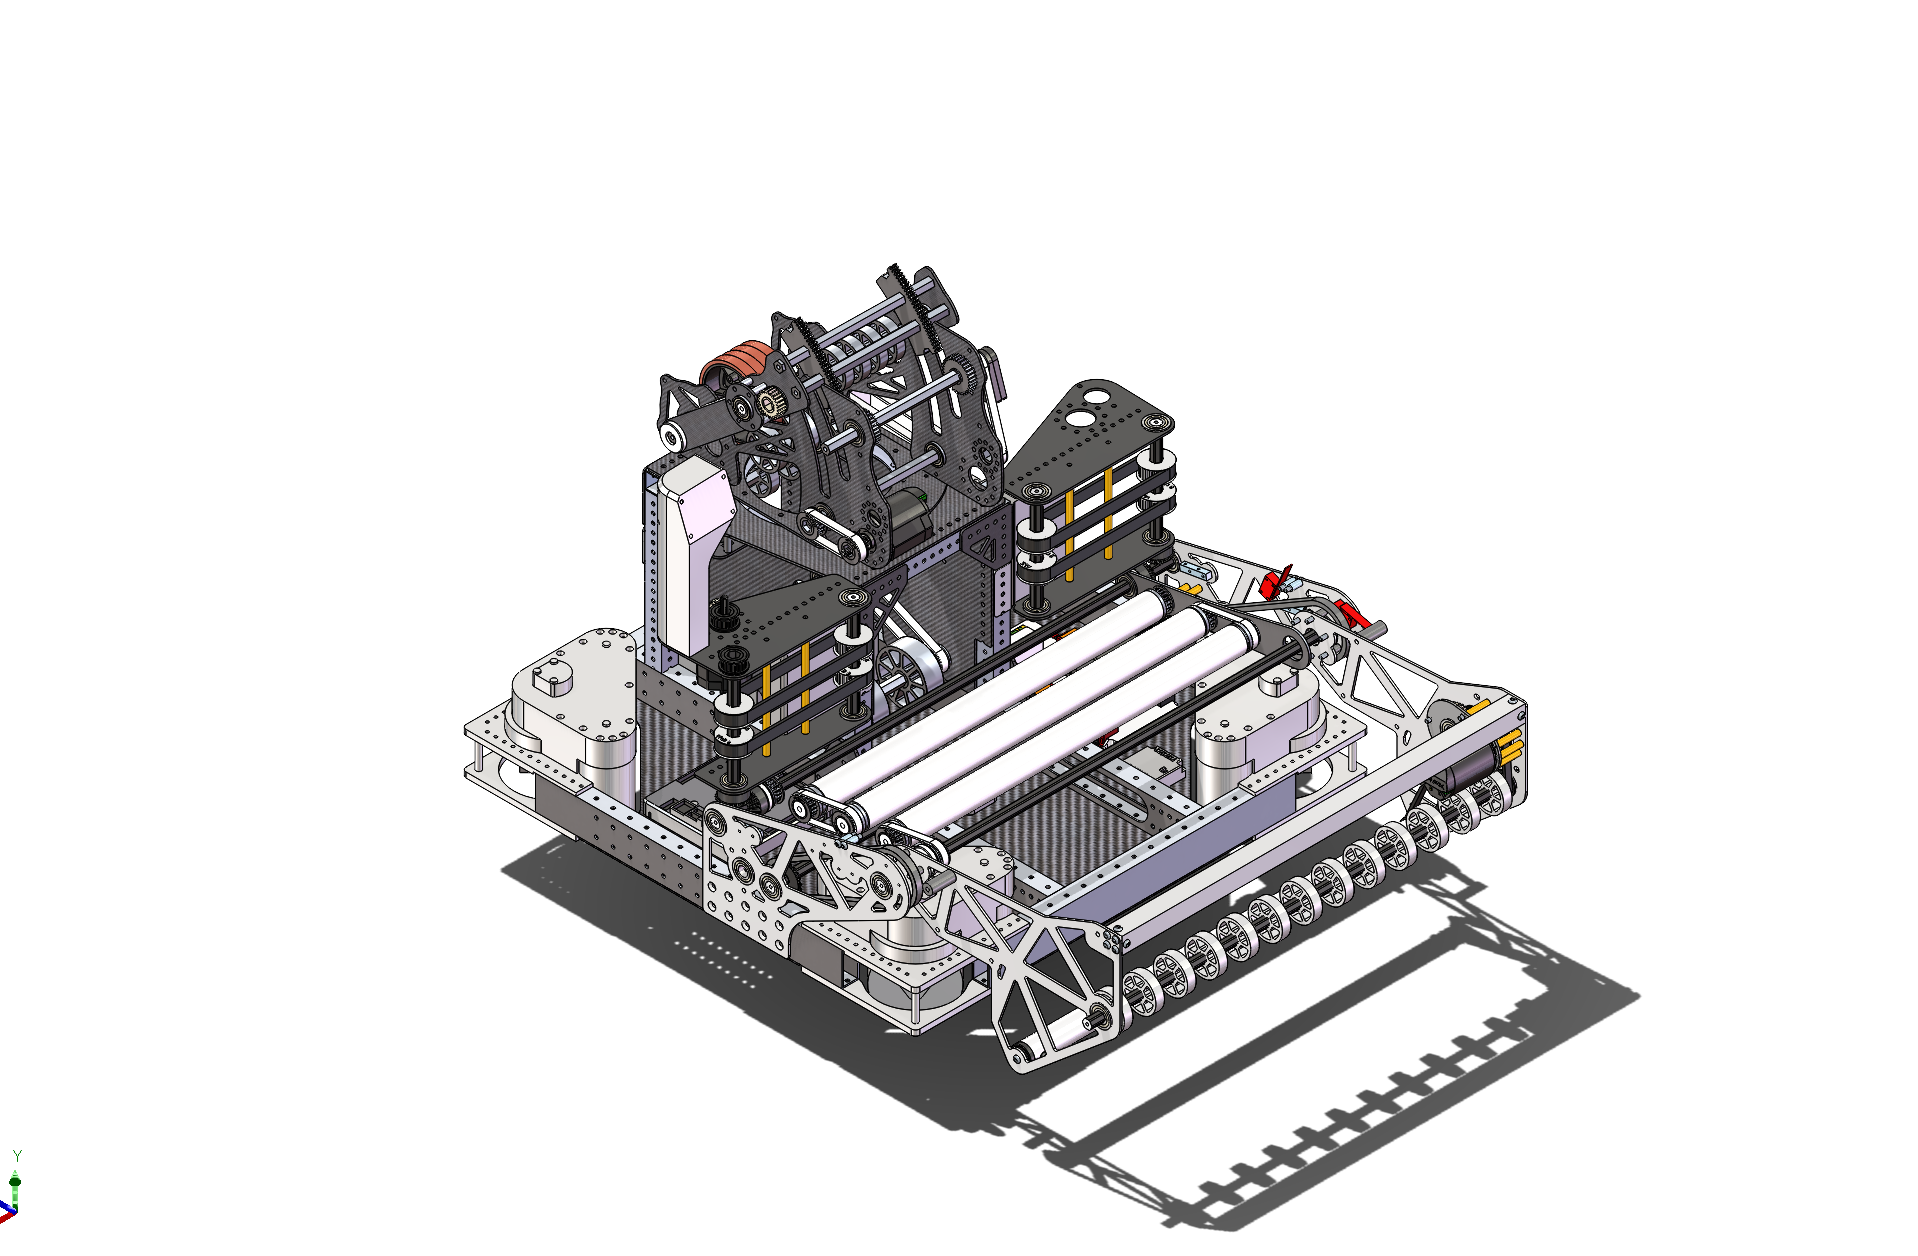
THE FIELD BOOK
Contents.
Use this index to follow the design from the full robot down to individual files. Every image and export below comes from the project material I supplied.
FRC SYSTEMS / 01
The complete
robot.
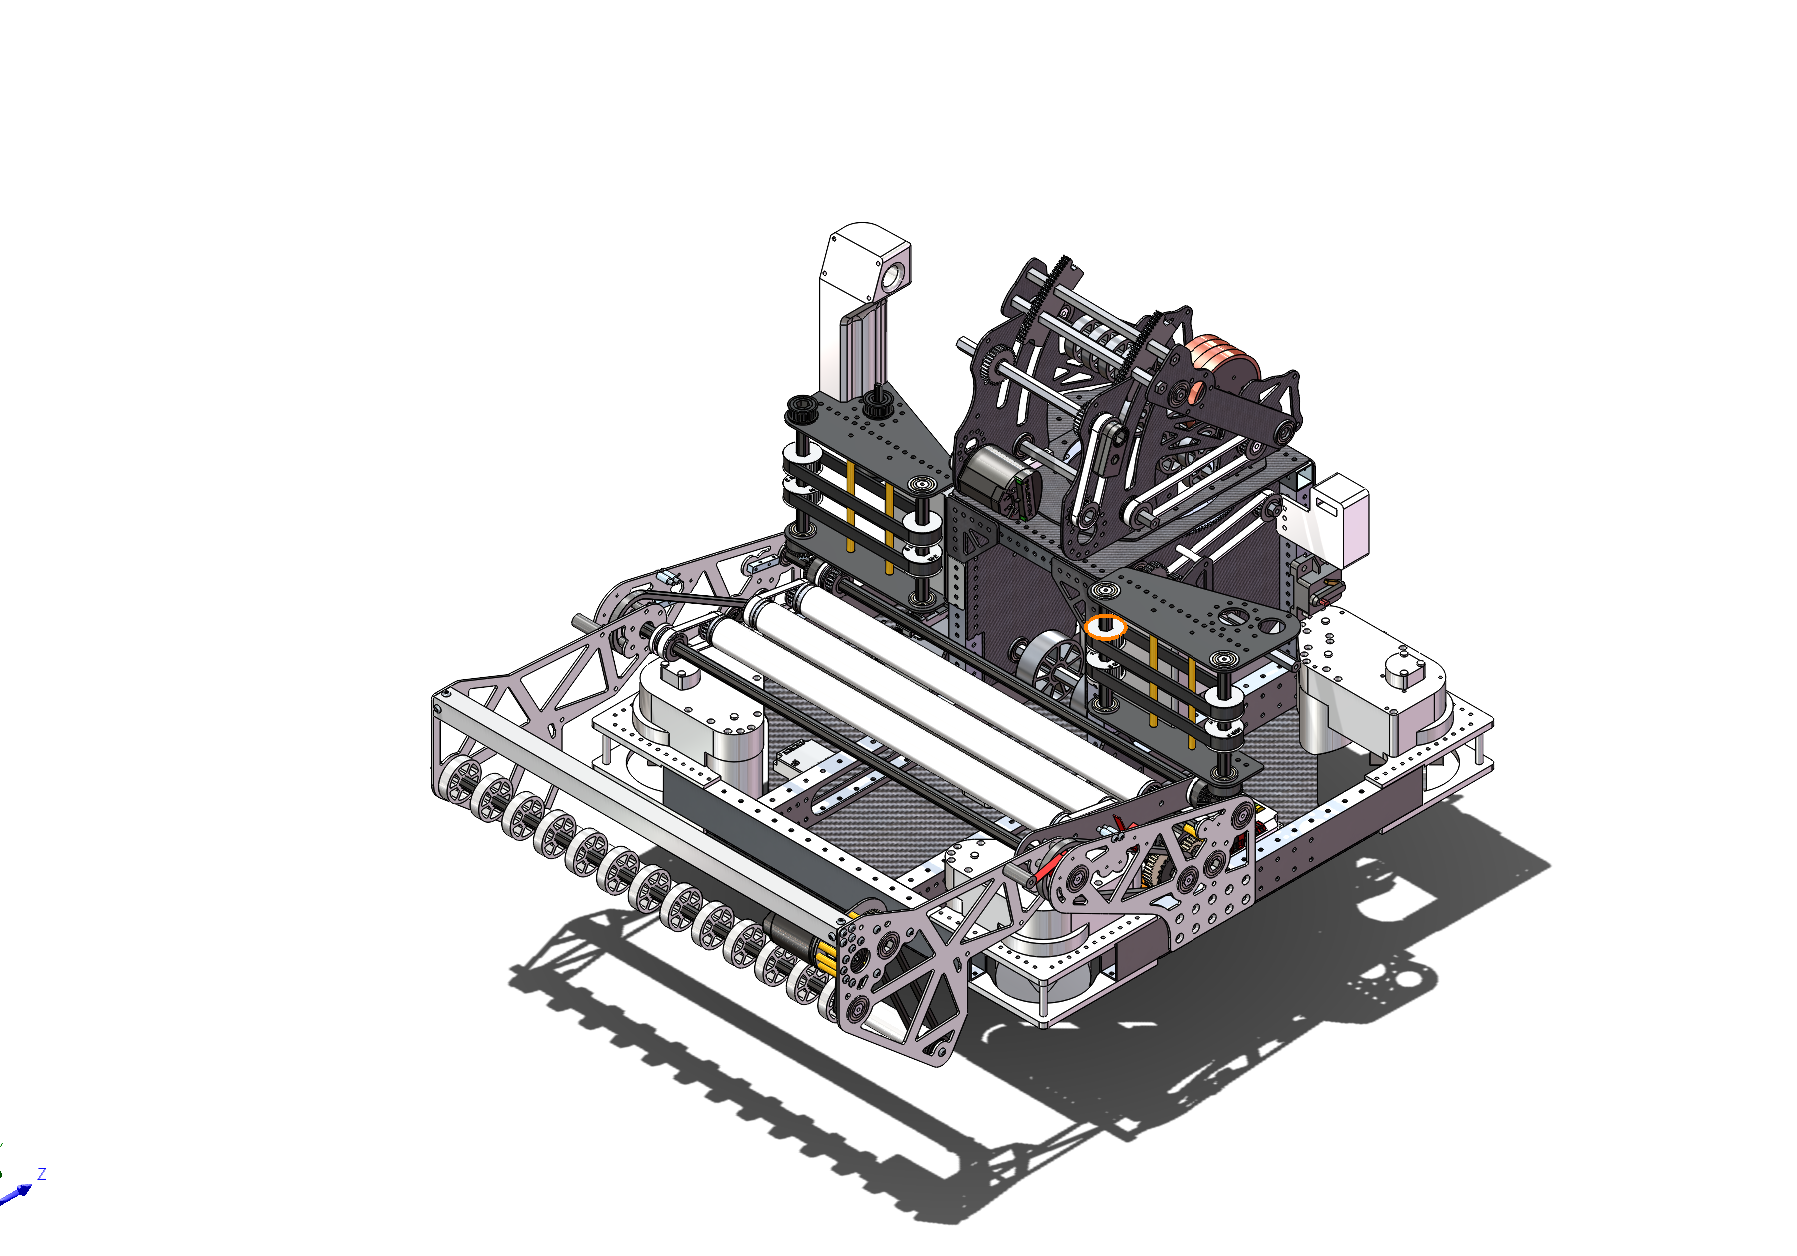
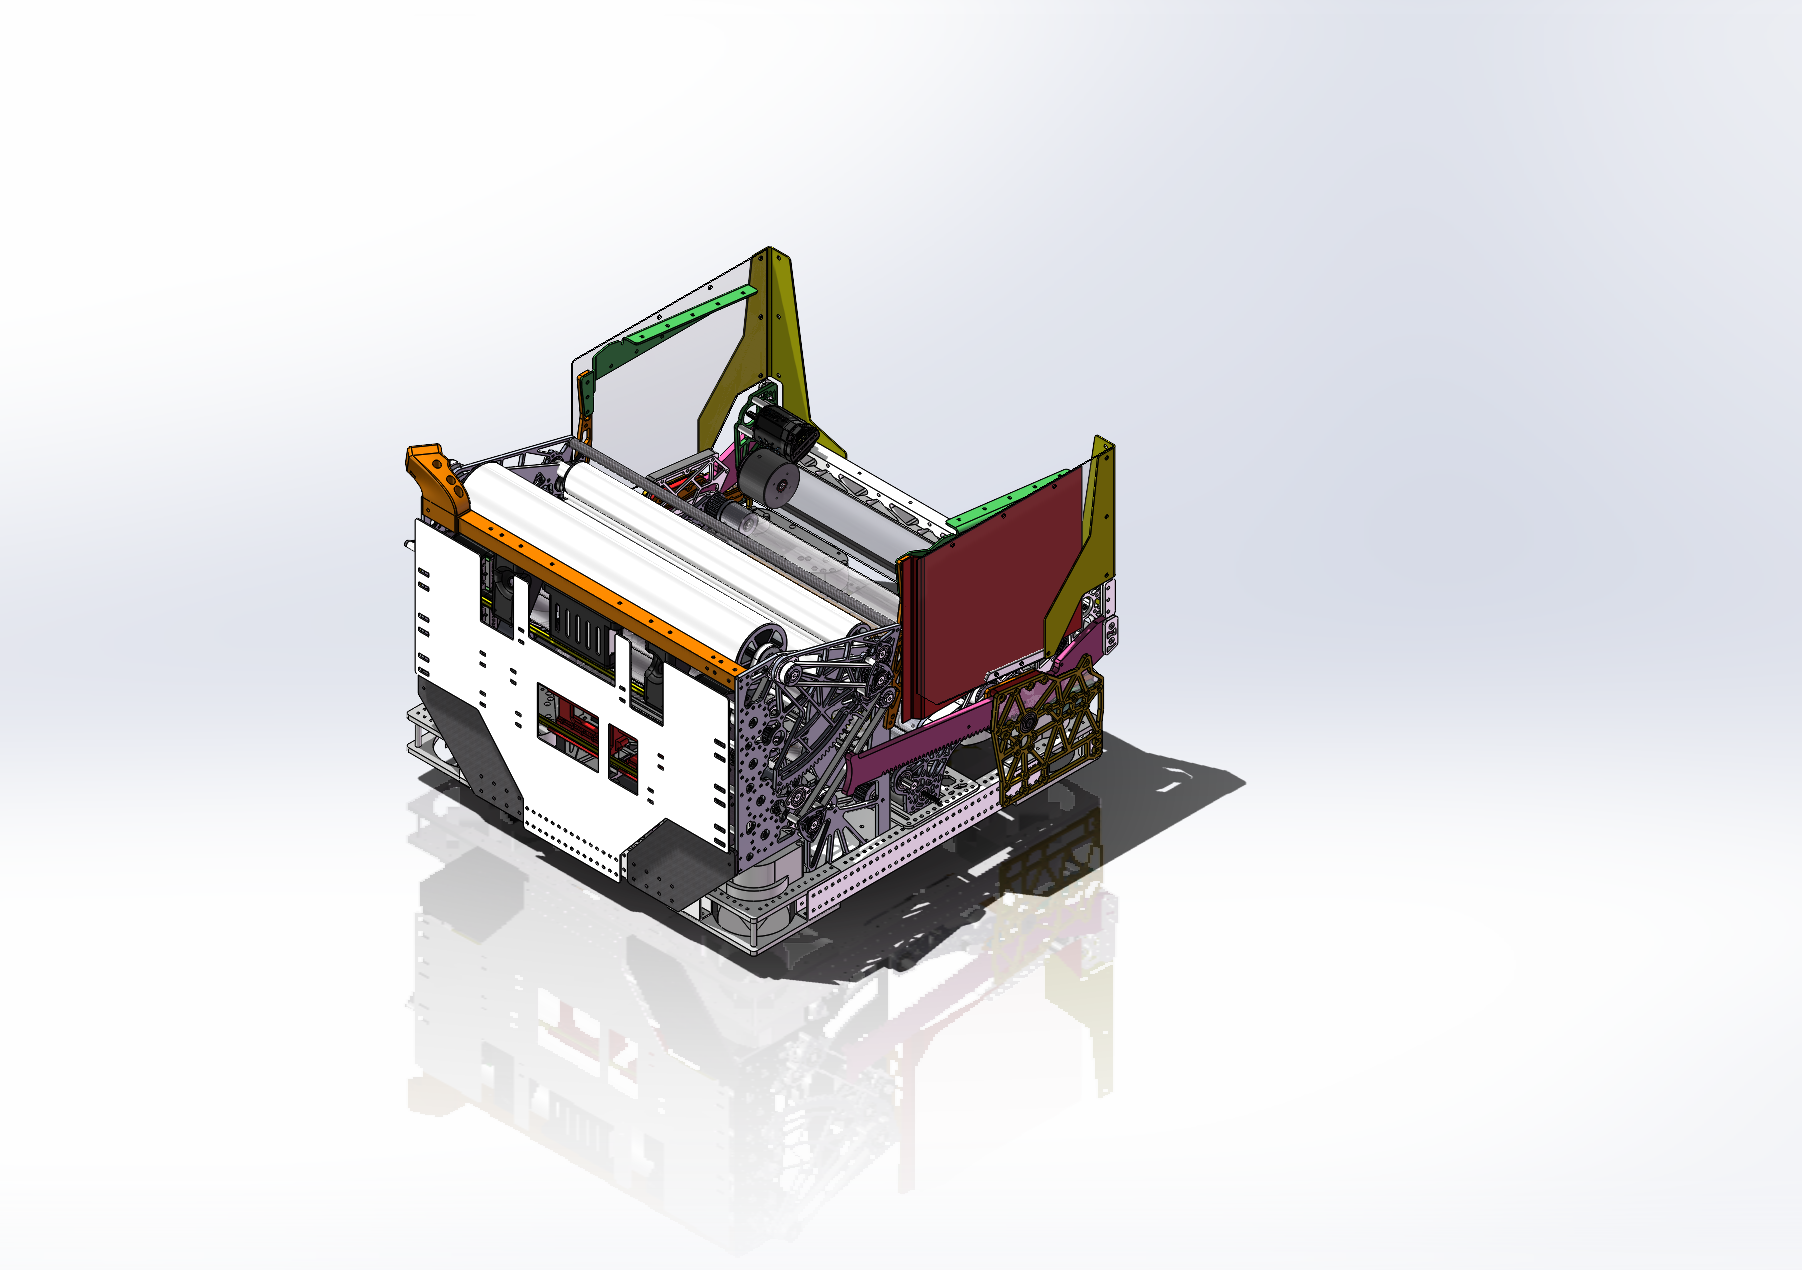
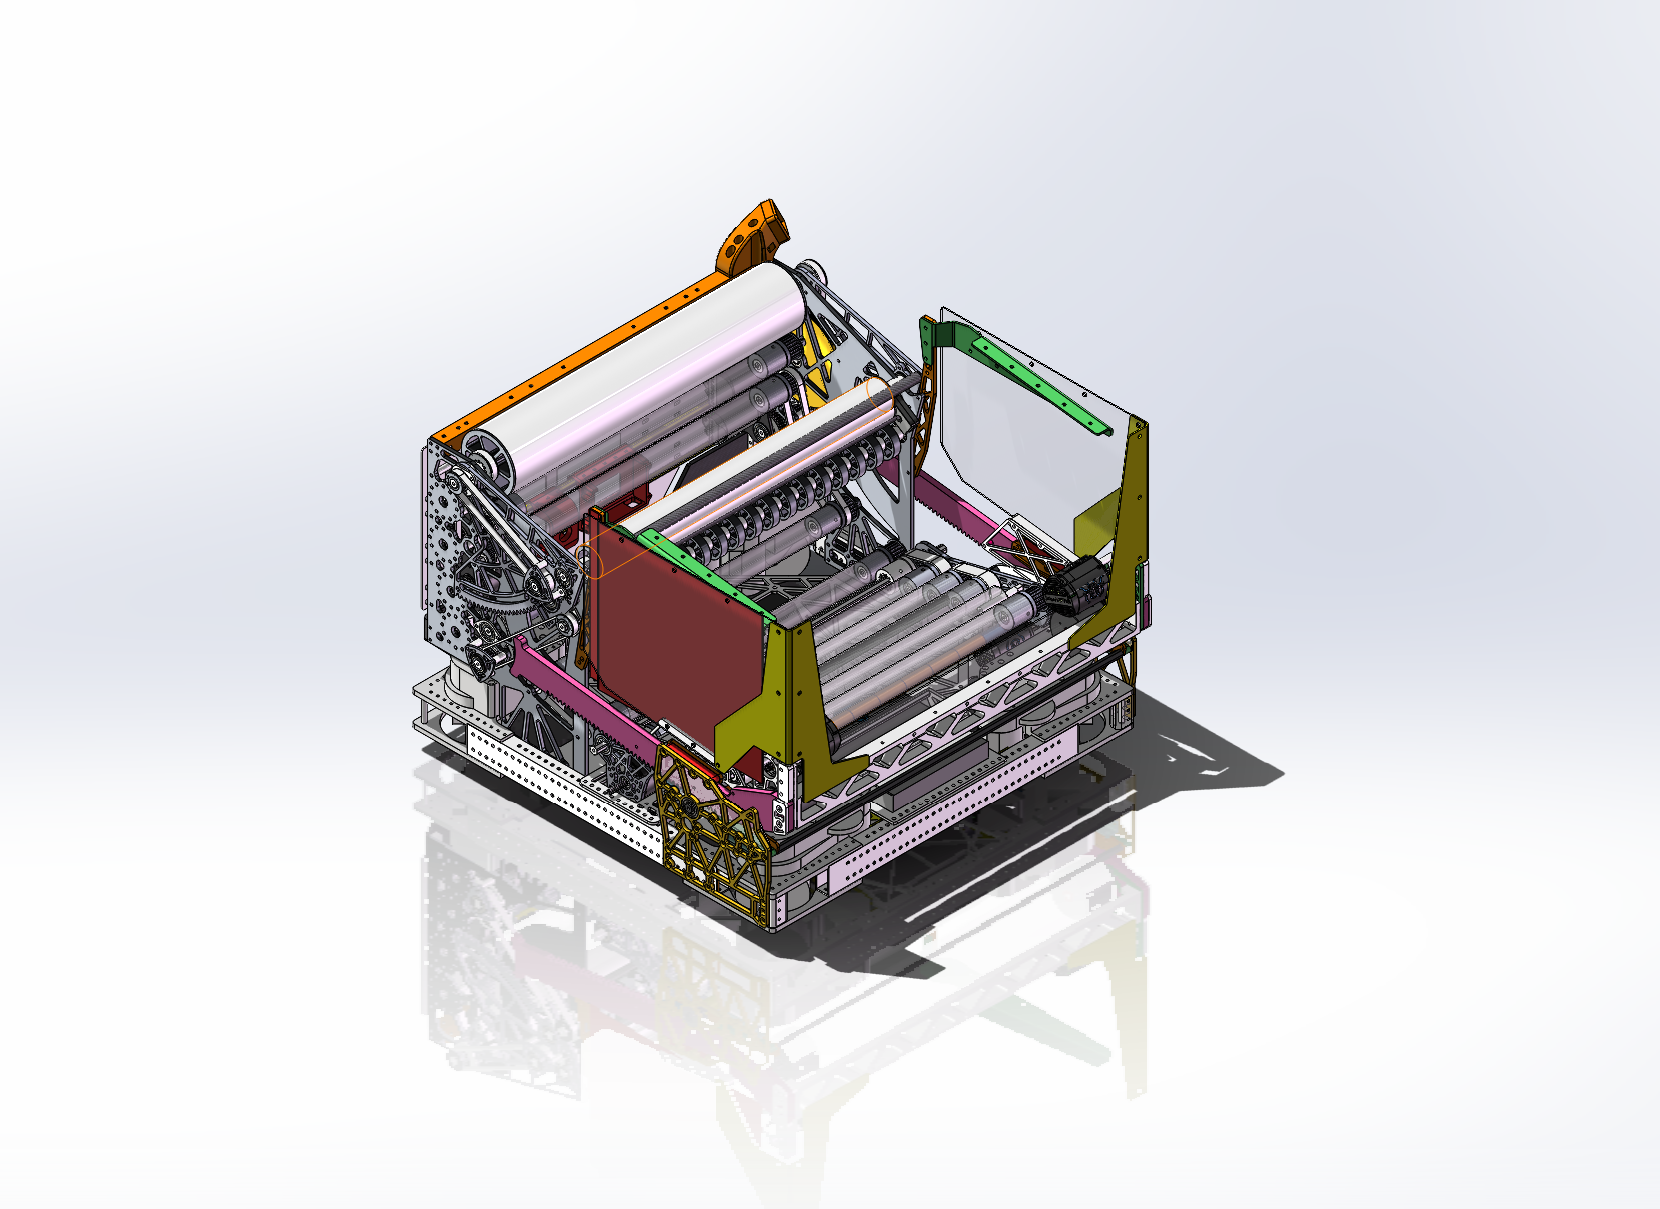
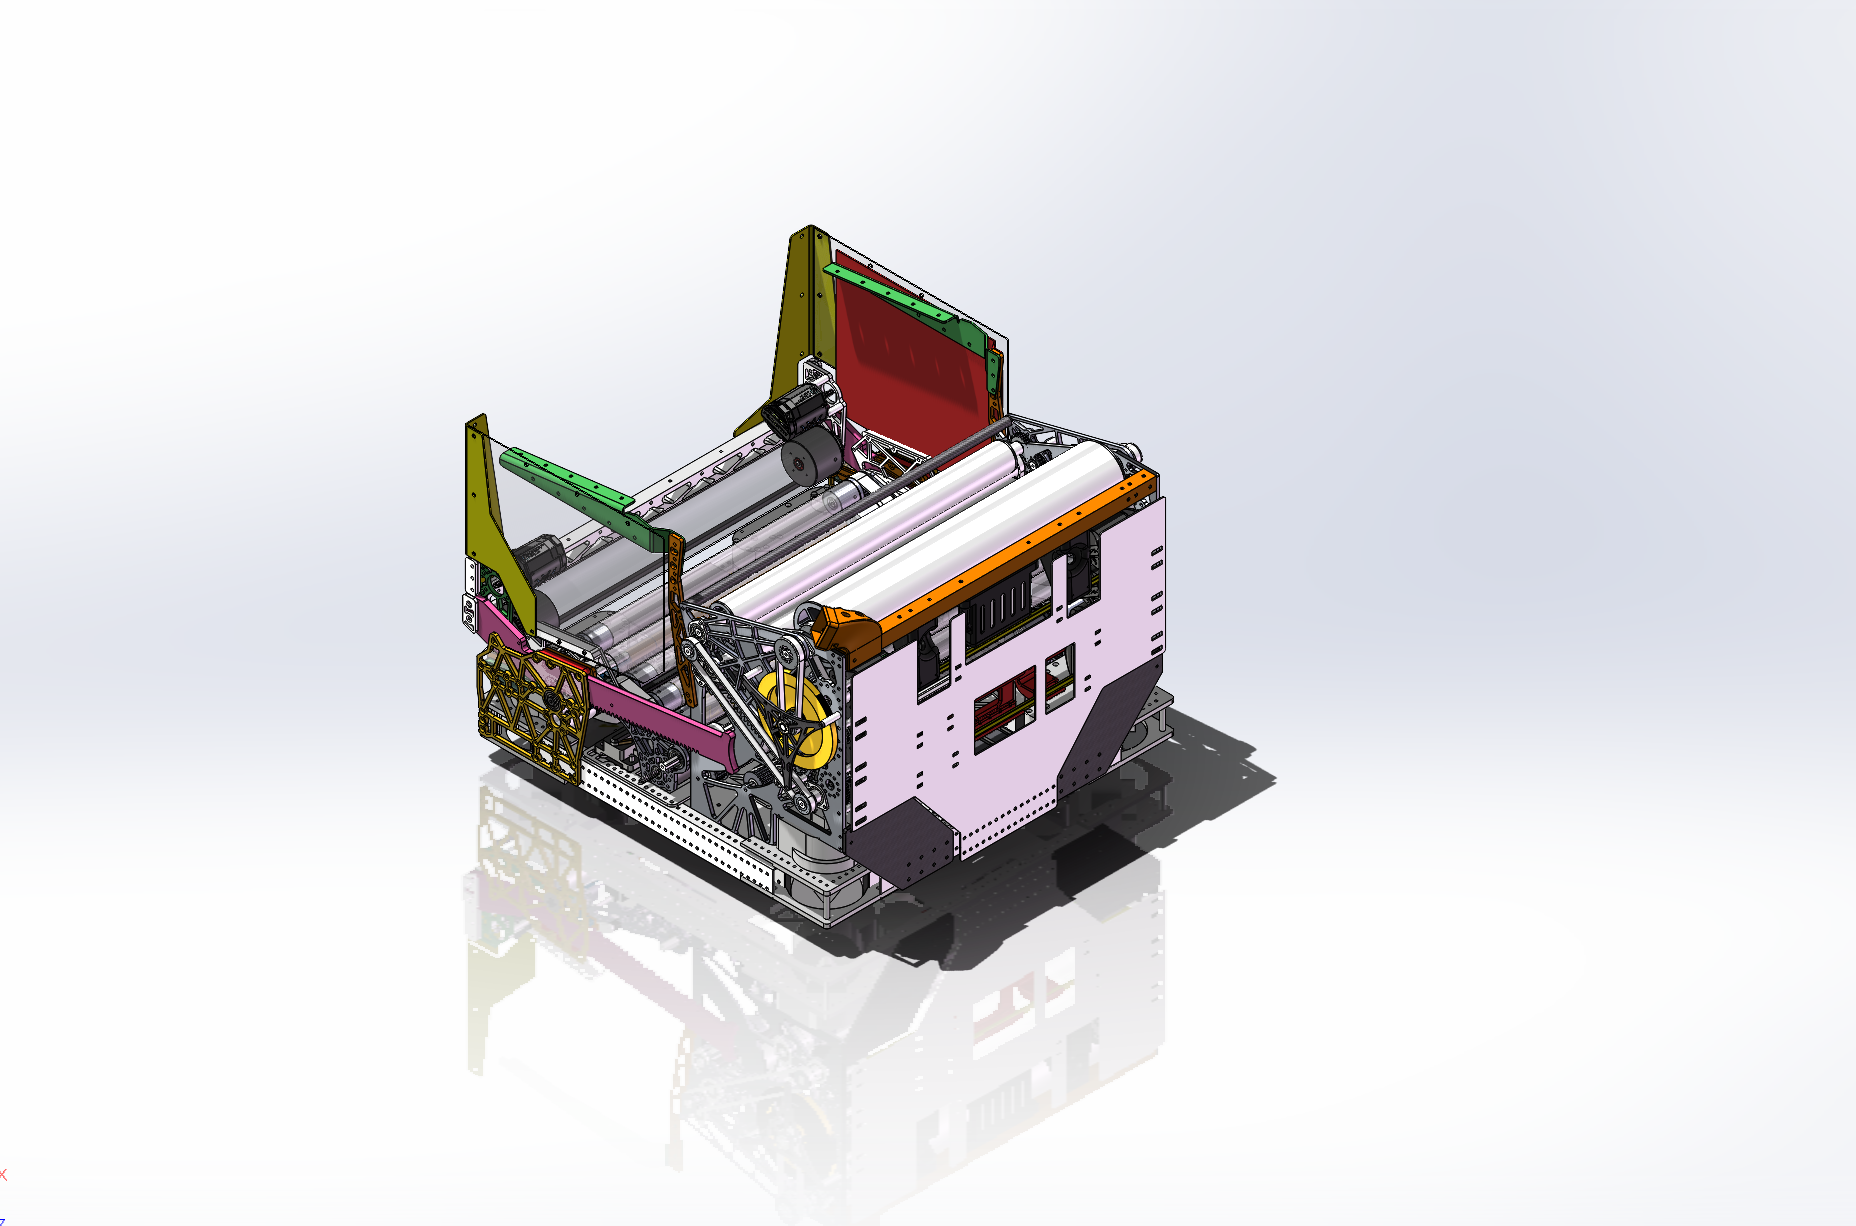
A full assembly makes the relationships between mechanisms visible: the intake path, upper structure, chassis, and the space each system leaves for the others.
What the archive shows
- Full robot assemblies saved in the 3.5 and 3.7 source folders.
- Separate subassemblies for intake, turret, hopper, chassis, and climb.
- Multiple CAD views of both open and panelled configurations.
FRC SYSTEMS / 02
Intake
system.
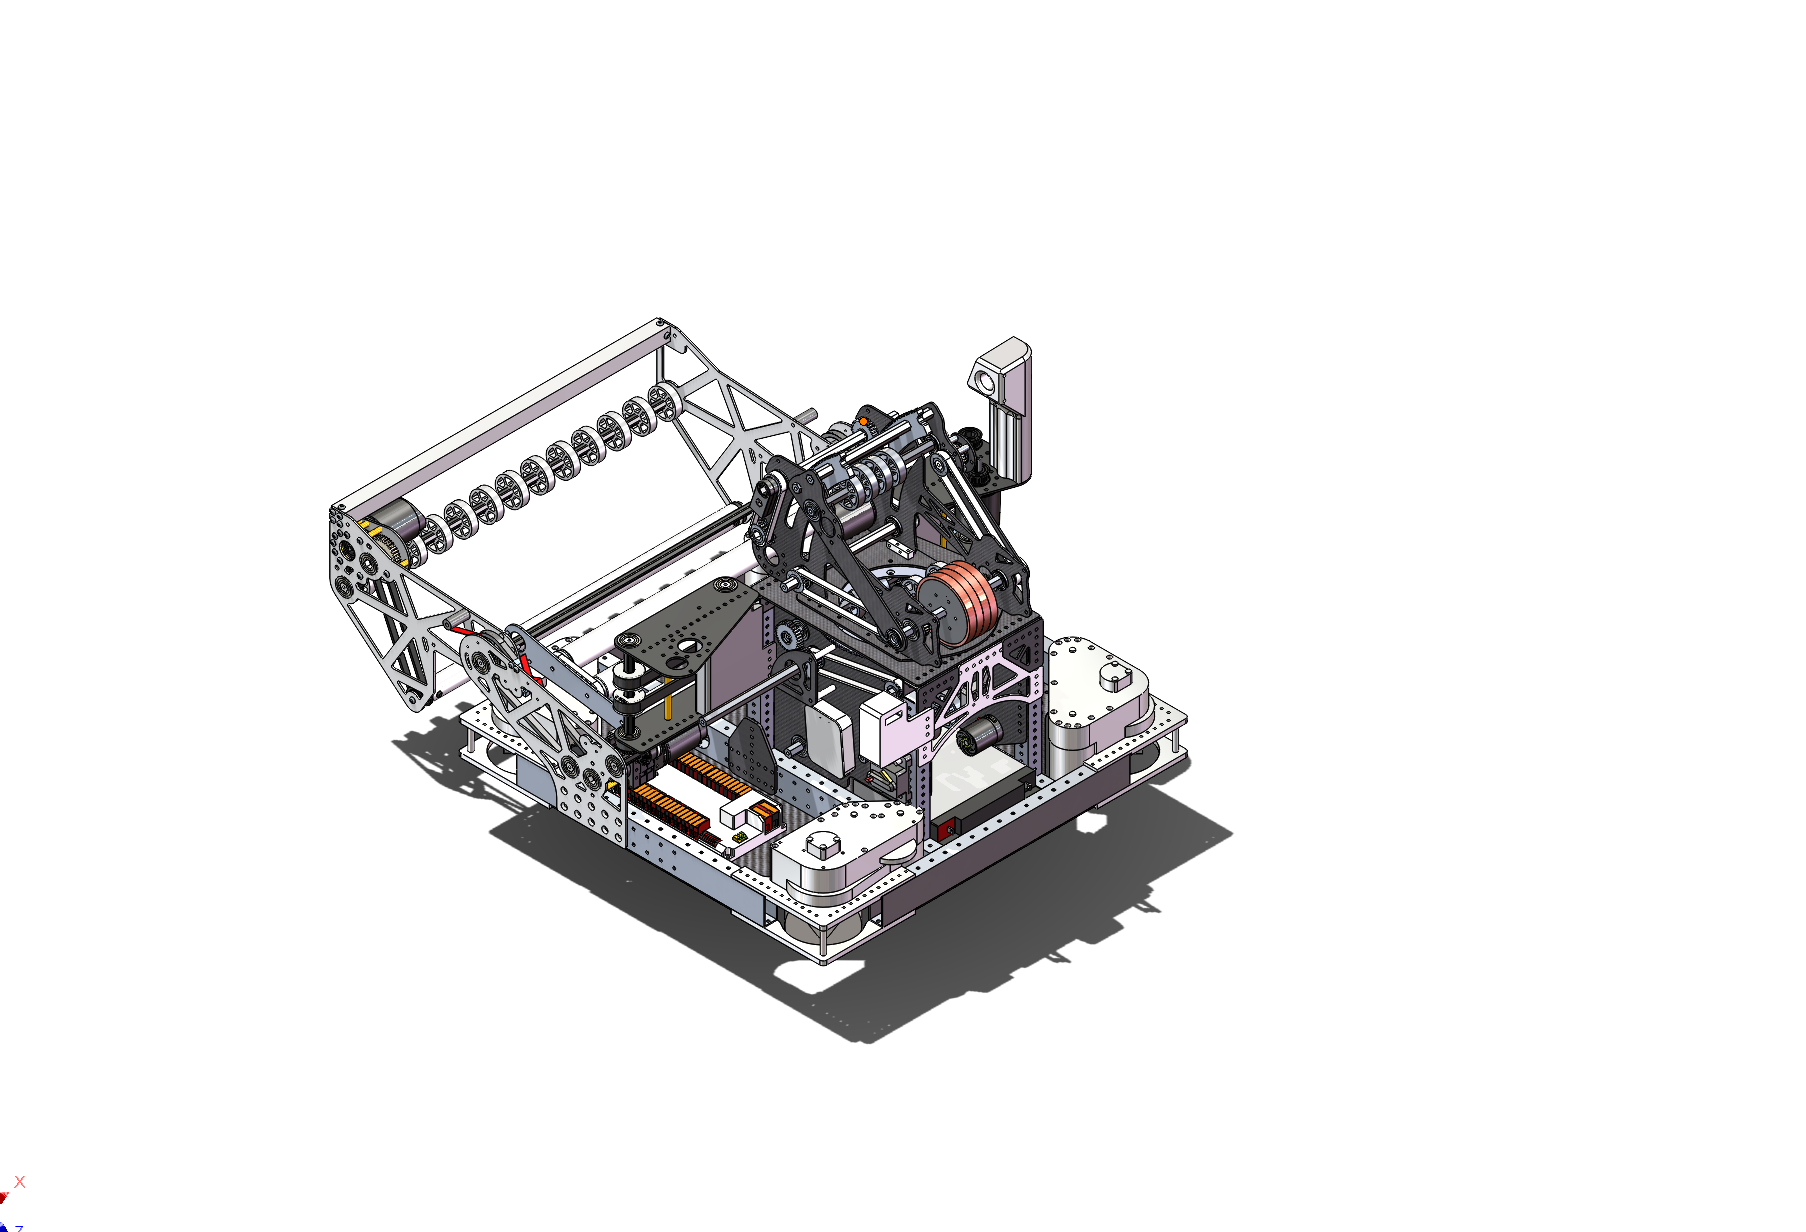
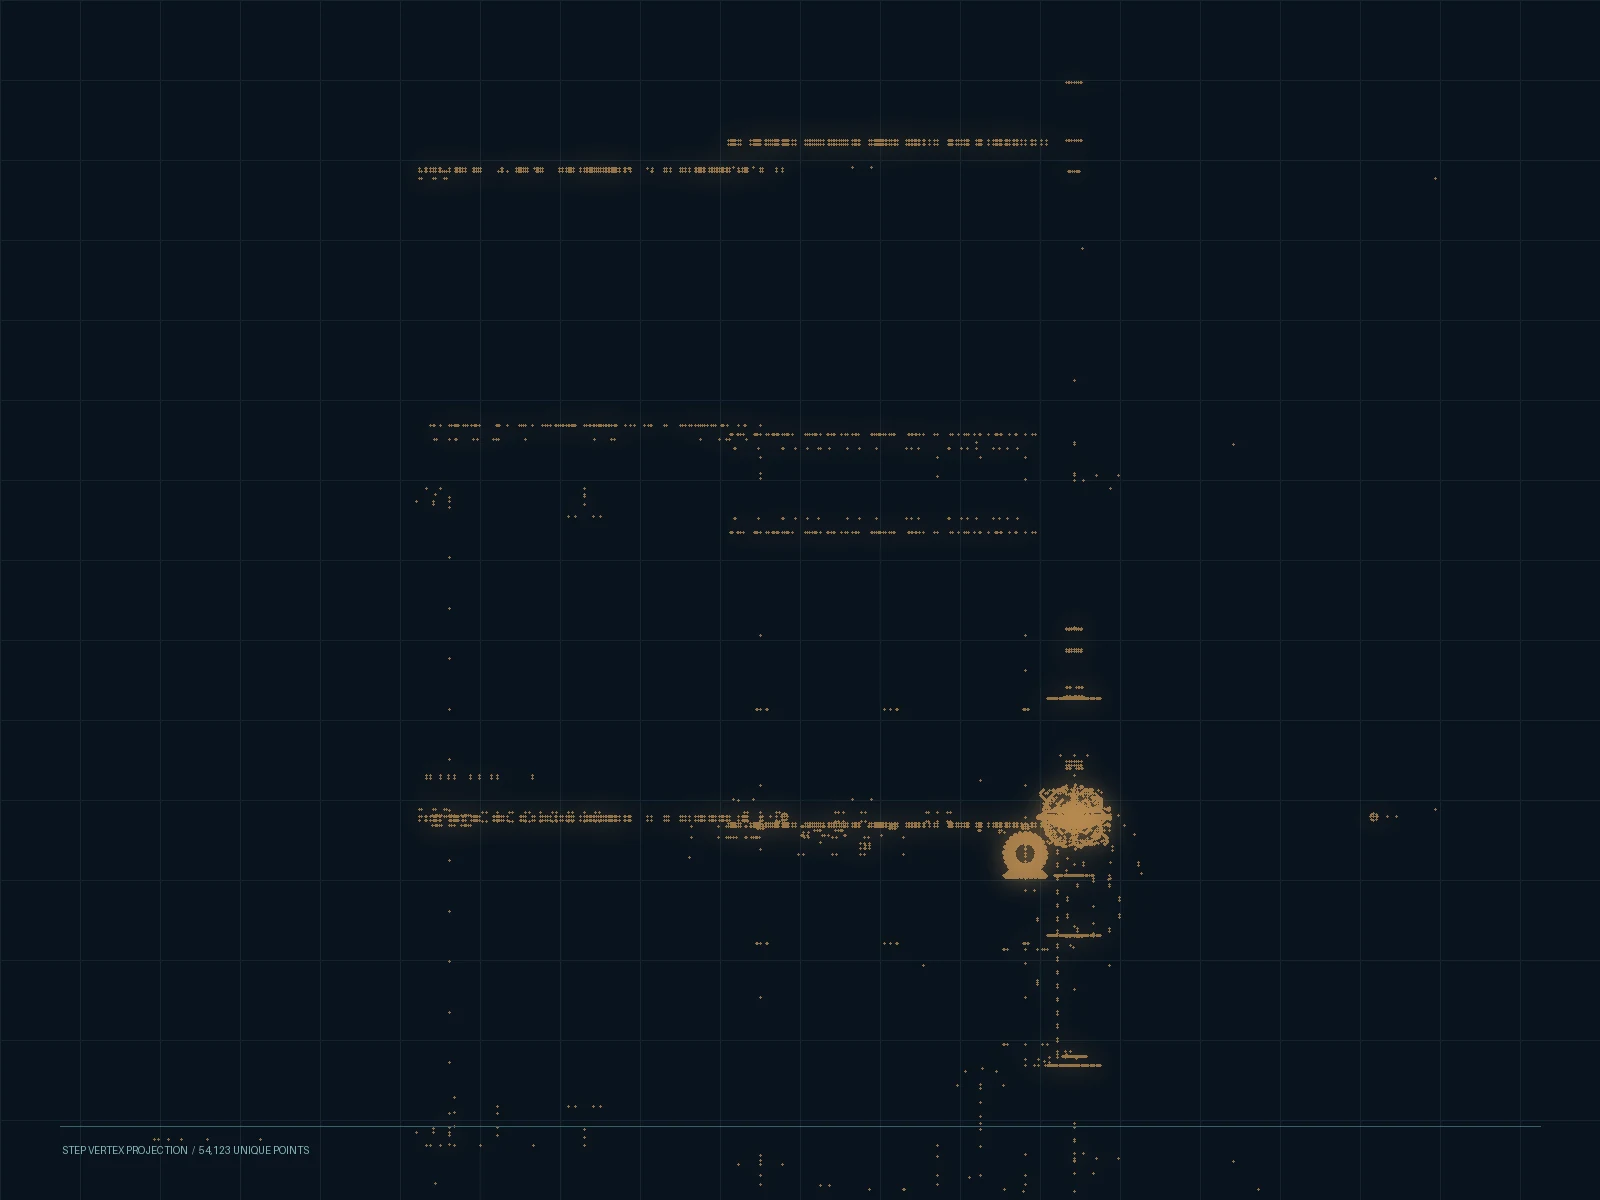
The intake is documented as a native SolidWorks assembly and a STEP export. The saved versions make it possible to inspect the mechanism beyond a screenshot.
In the source material
- Intake assemblies appear in both the 3.5 and 3.7 robot folders.
- The 3.7 STEP export can be opened independently in a CAD viewer.
- The point projection here is generated from that export’s geometry.
FRC SYSTEMS / 03
Turret
revisions.
A design is easier to understand when its revisions remain visible. The source archive includes distinct turret V2 and V3 assemblies, with V3 also present in the later 3.7 robot folder.
Saved progression
- Versioned native SolidWorks turret assemblies.
- Later robot folder retains the V3 turret.
- Full robot views show how the upper assembly fits within the system.
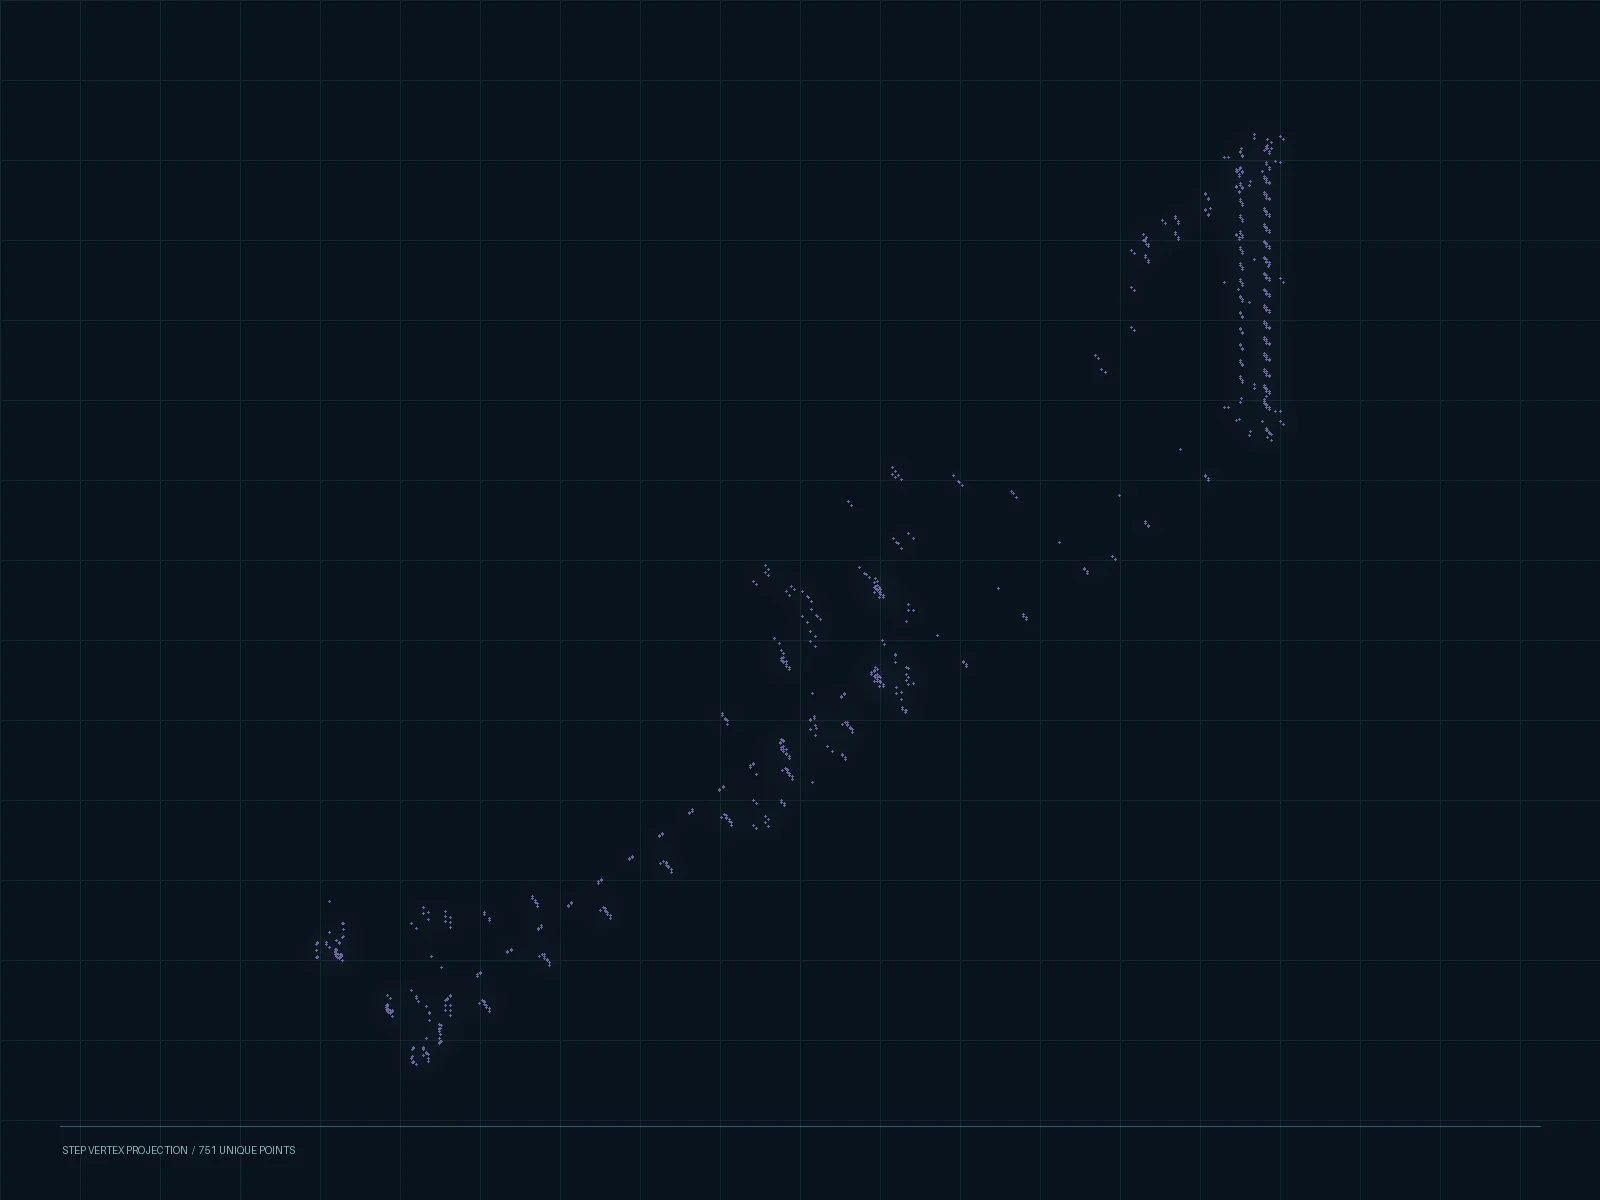
FROM ACTUAL EXPORT
FRC SYSTEMS / 04
Hopper
assembly.
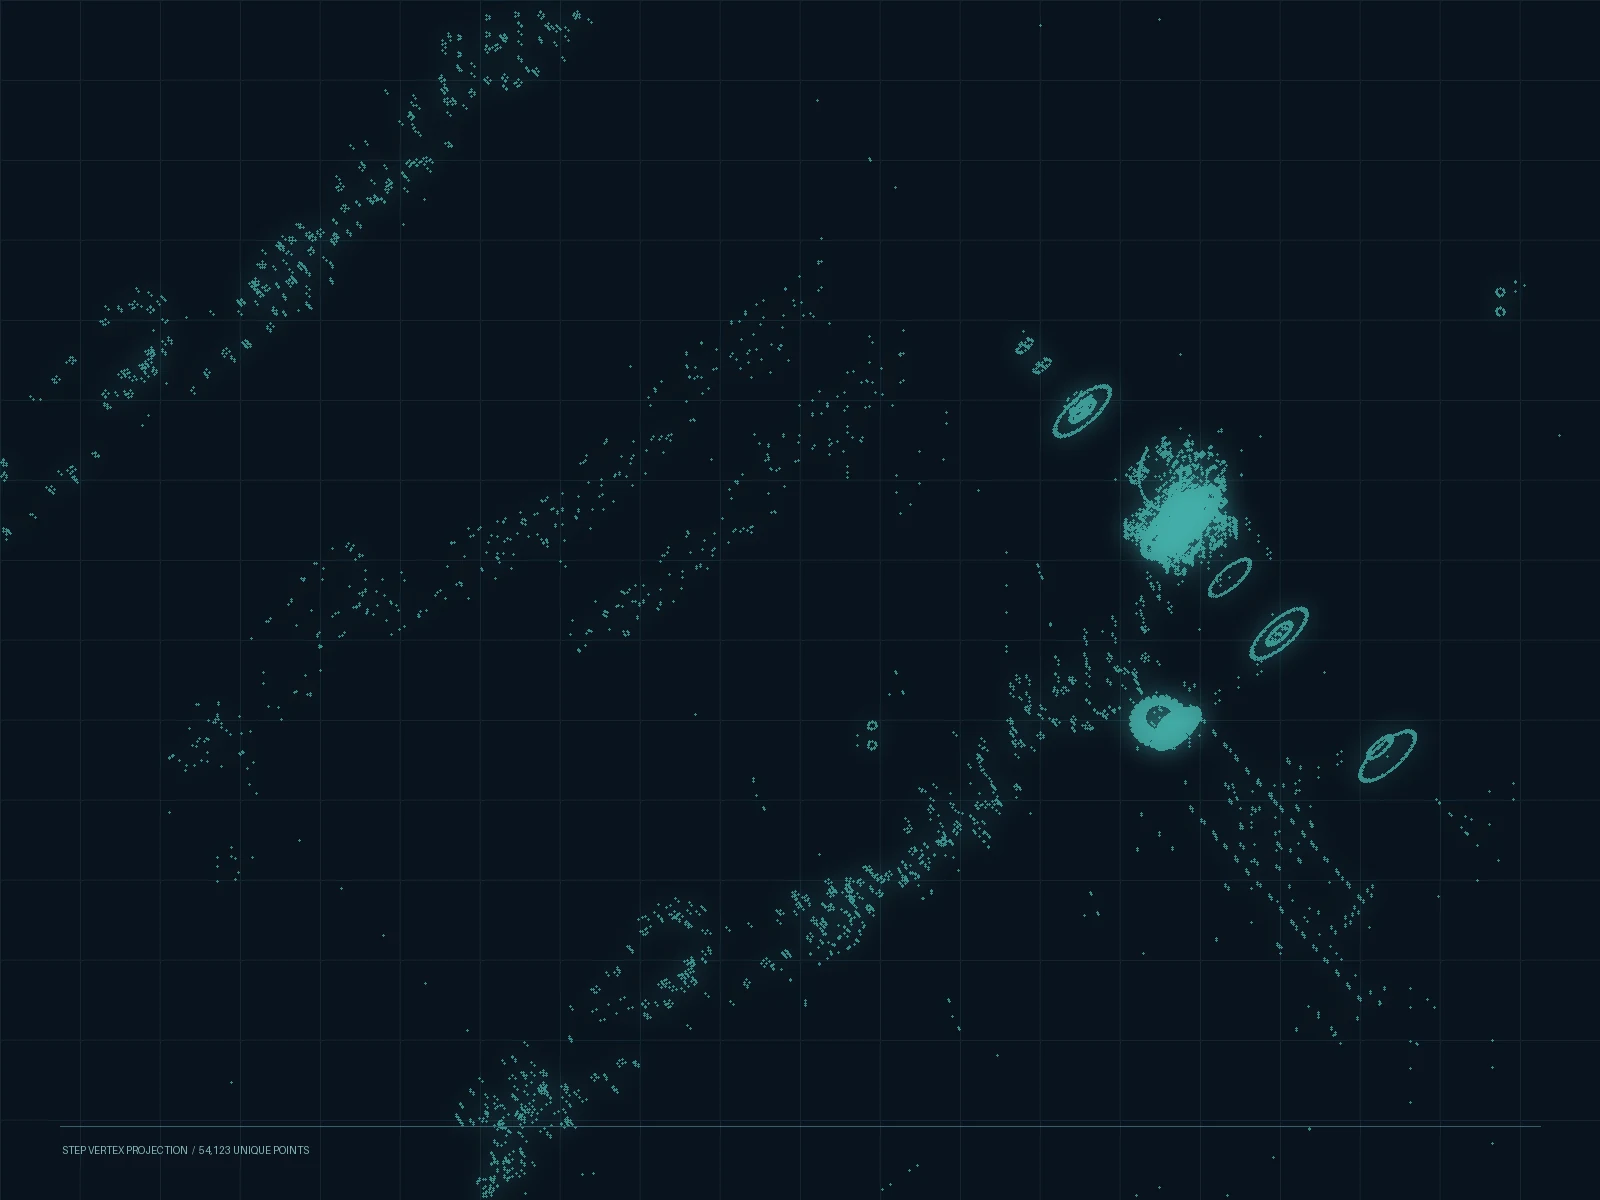
This subassembly has its own STEP export in the 3.5 robot files. The projection at left is derived from its geometric points rather than an invented render.
Available to inspect
- Separate hopper assembly and STEP export.
- Interactive geometry preview in the next chapter.
- Downloadable STEP file for independent review.
THE RECORD / 05
Look inside
the geometry.
Drag to rotate a point projection made from Cartesian data in the STEP exports. Switch between intake and hopper. This is a geometry study, not a shaded surface model.
THE RECORD / 06
Original views
& source files.
Six screenshots from the CAD workspace, followed by selected exports that a visitor can open in their own tools.
Selected exports
OPEN / INSPECT / VERIFYThe supplied archives also contain native SolidWorks parts and assemblies. A full July 13 assembly STEP is too large for this site’s direct download. Standard and vendor components in the archives belong to their respective makers.
The person
behind the work.
I’m Justin Yin. I use CAD to turn a mechanism idea into a robot system that can be inspected, revised, and built. This field book starts with my FRC 2026 design files and the iterations kept within them.
As I share more engineering projects, this index can grow into a fuller record of the problems I chose, the decisions I made, and the results I can show.
BACK TO INDEX